gimbal control board revision
With the new gearbox based mech chassis for Super Mega Microbot 2, the old gimbal controller would need some updates. It has these new features/capabilities:
- Higher input voltage: The old system ran at 2S, so 7.2V nominal. Now we’re running at 5S, so 18.5V nominal.
- RS485 data: The HerkuleX based robot used TTL level data communications. moteus uses RS485.
- Daisy chained power: With the new raspberry pi based computer in the turret, I now need to have an additional power and data port up on the mobile part of the turret.
- No camera passthrough: Similarly, since the camera is directly attached to the raspberry pi 3, I don’t need to mess with having a connector to pass it through anymore.
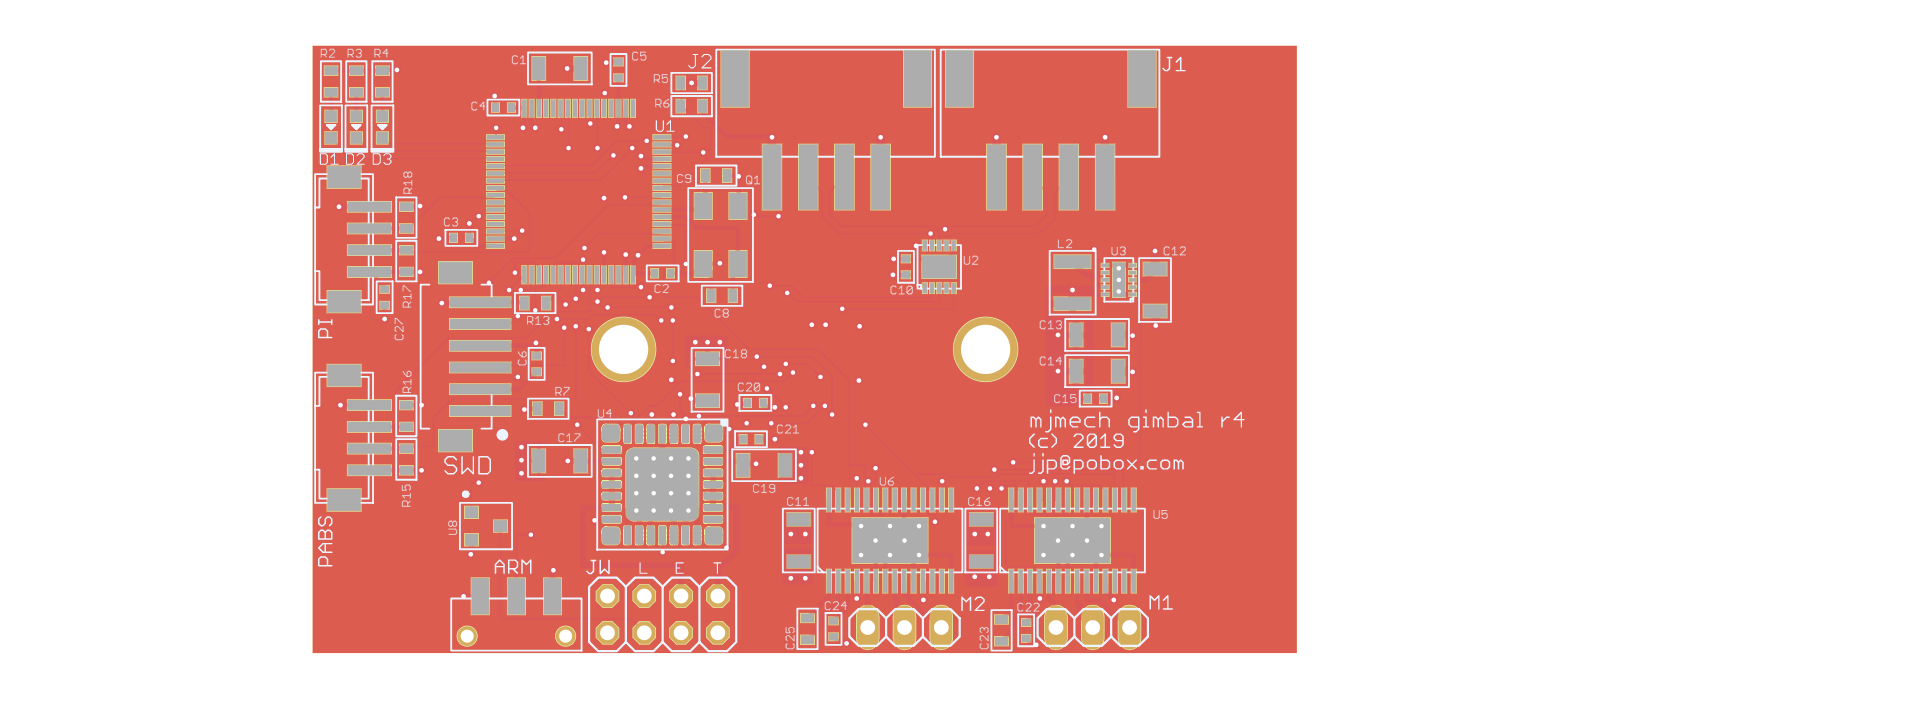
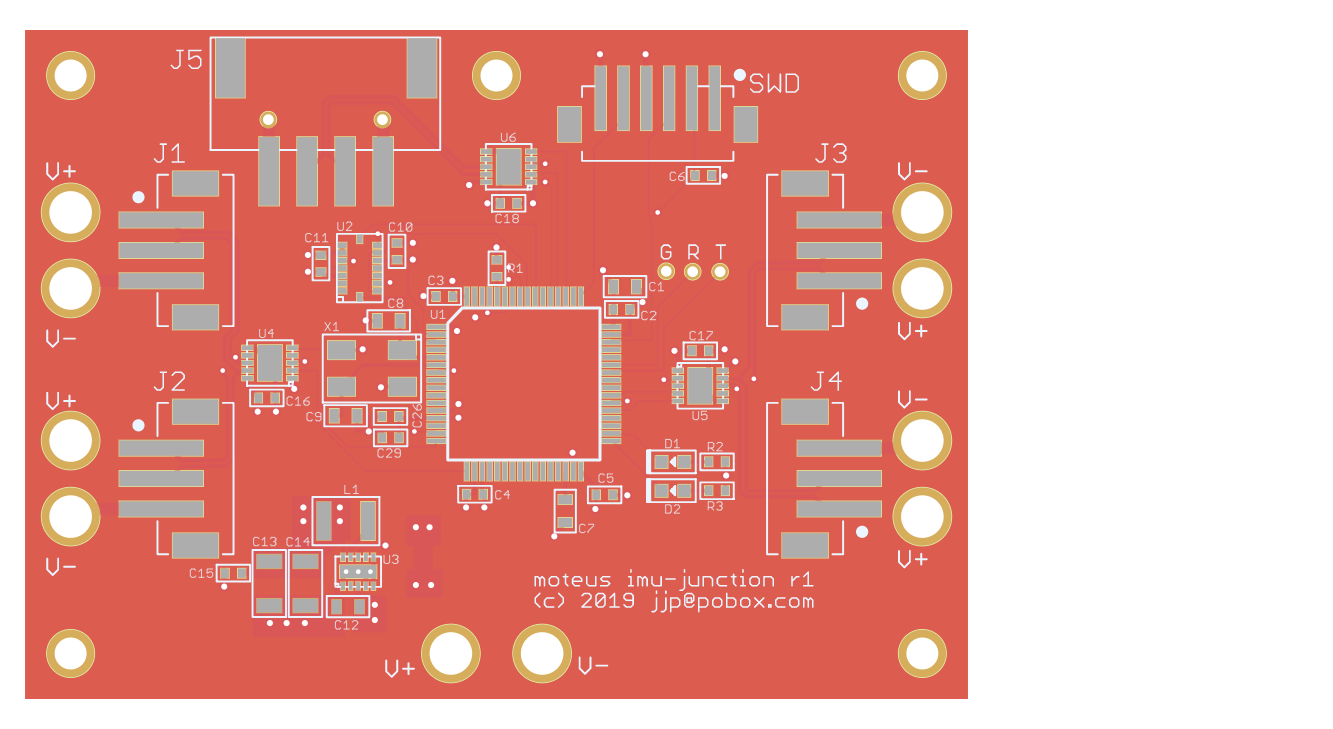
PCB rendering